• Jeonghyun Byun
  • PUBLICATIONS
  • STUDY
  • BLOG
  • PHOTOGRAPHY

    Jeonghyun Byun

    PUBLICATIONS

    Jeonghyun Byun

    Jeonghyun Byun

    Fulbrighter | PostDoc @VijayKumarGroup, GRASP, UPENN | PhD in Robotics & Drone

    • Philadelphia, PA, USA
    • Email
    • Curriculum Vitae
    • Research Statement
    • Google Scholar
    • Github
    • LinkedIn

    Safety-critical bilateral teleoperation for omnidirectional aerial manipulation using force-sensorless haptic feedback

    Yubin Kim, Jinwoo Lee, Yongjun Lee, H. Jin Kim and Jeonghyun Byun

    IEEE/RSJ International Conference on Intelligent Robots and Systems · 2026
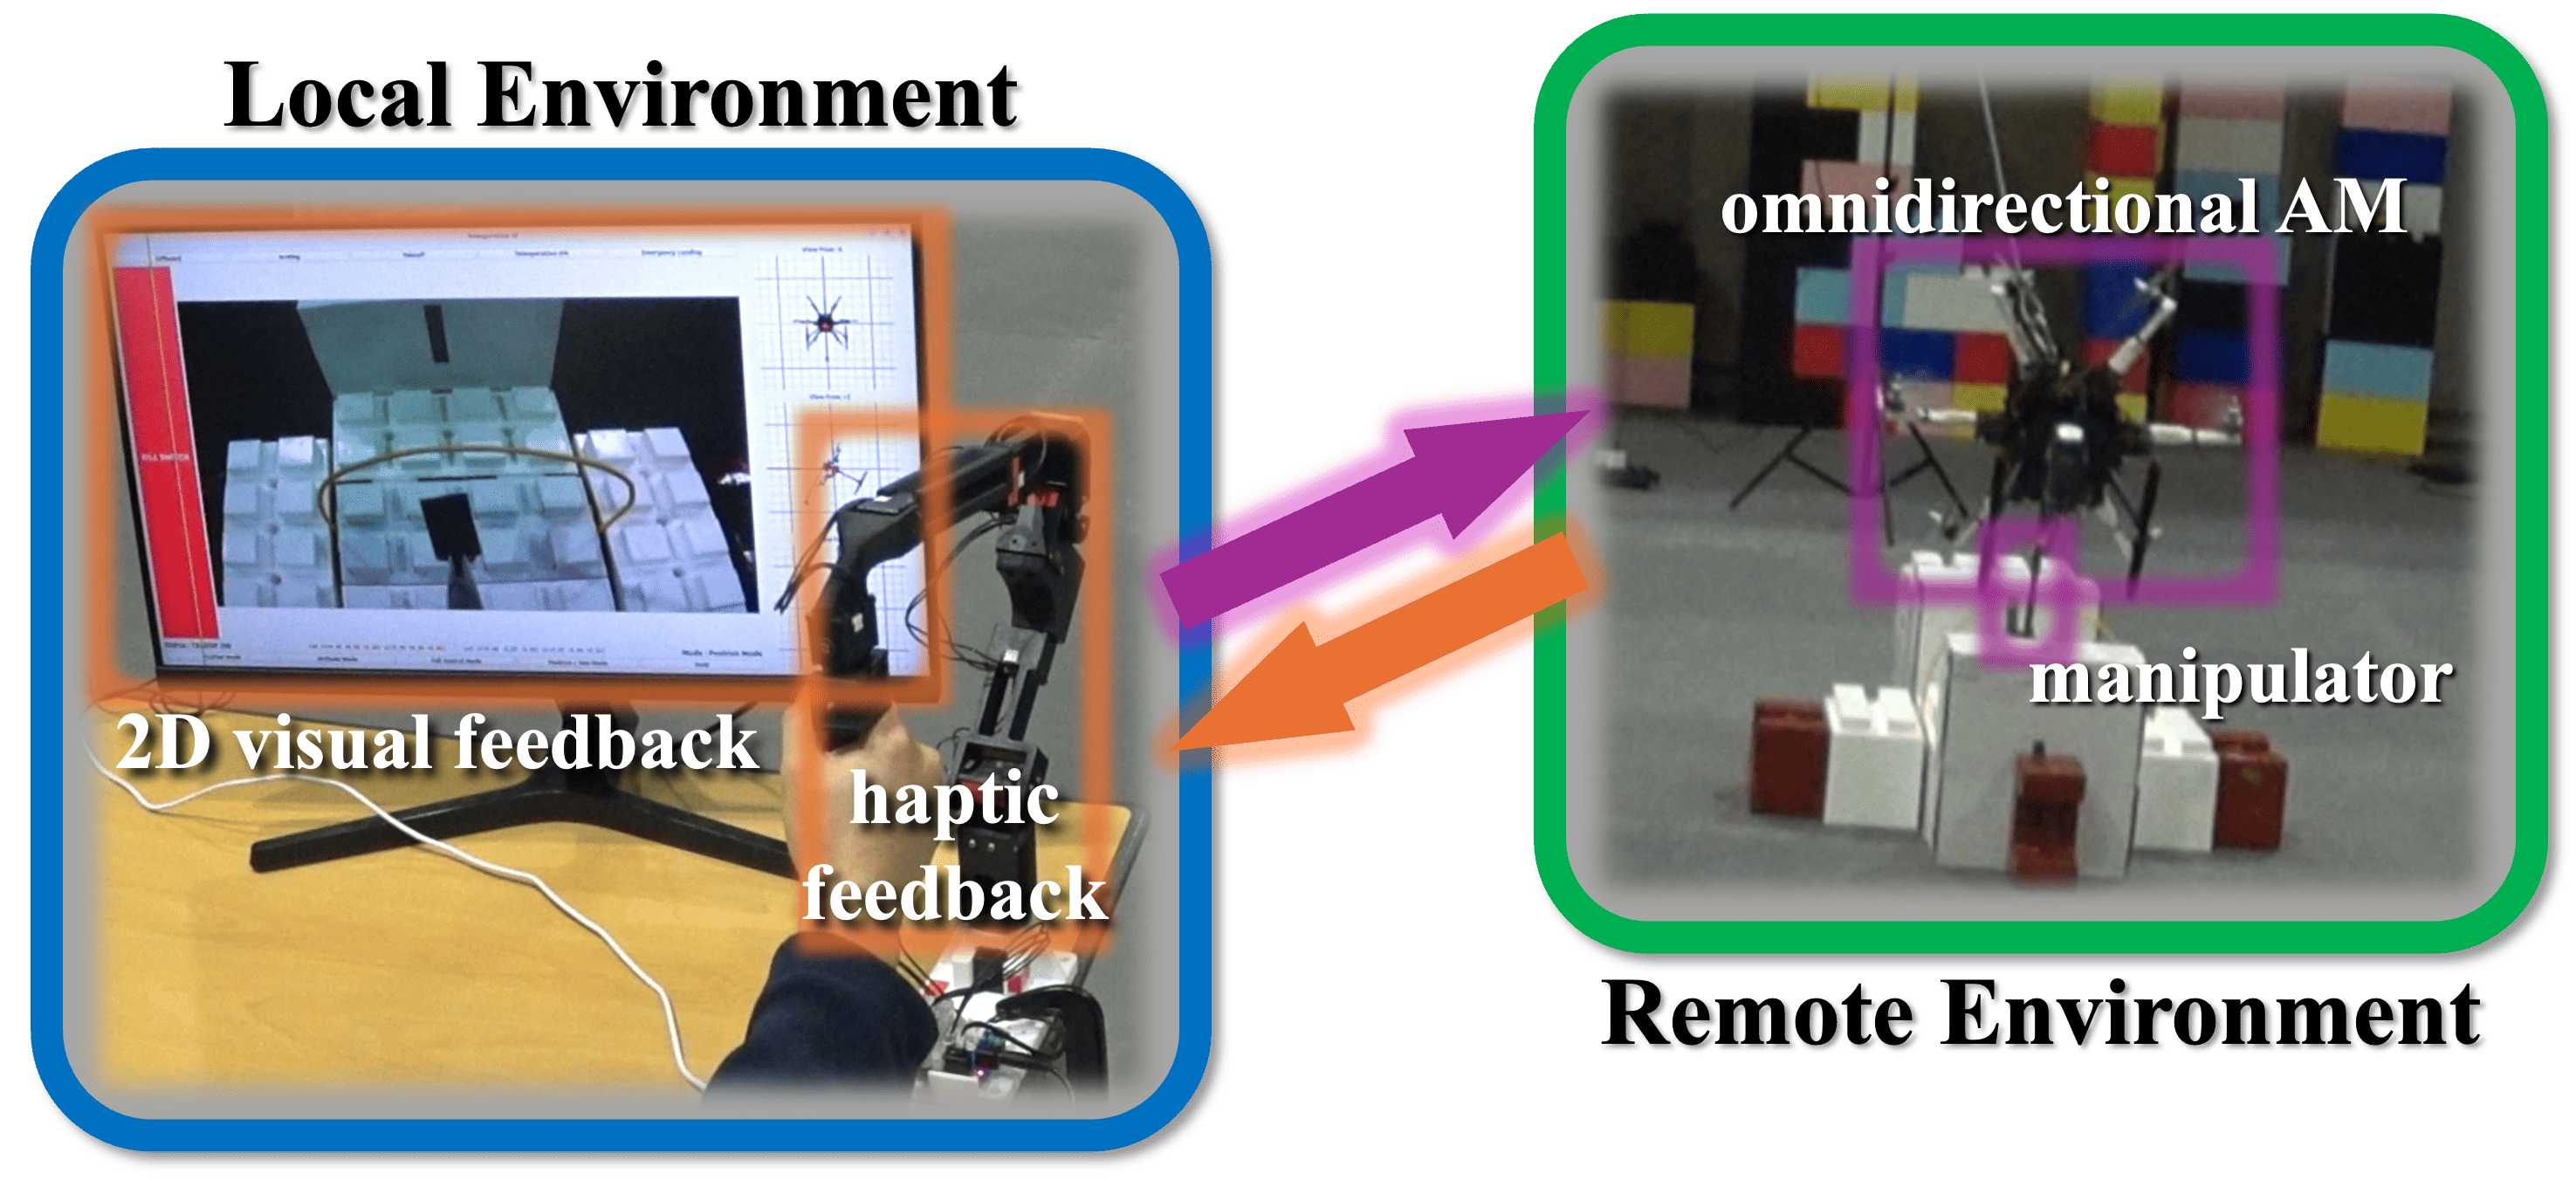
    Safety-critical bilateral teleoperation for omnidirectional aerial manipulation using force-sensorless haptic feedback

    Safety-critical control for aerial physical interaction in uncertain environment

    Jeonghyun Byun, Yeonjun Kim, Dongjae Lee and H. Jin Kim

    IEEE International Conference on Robotics and Automation · 2025
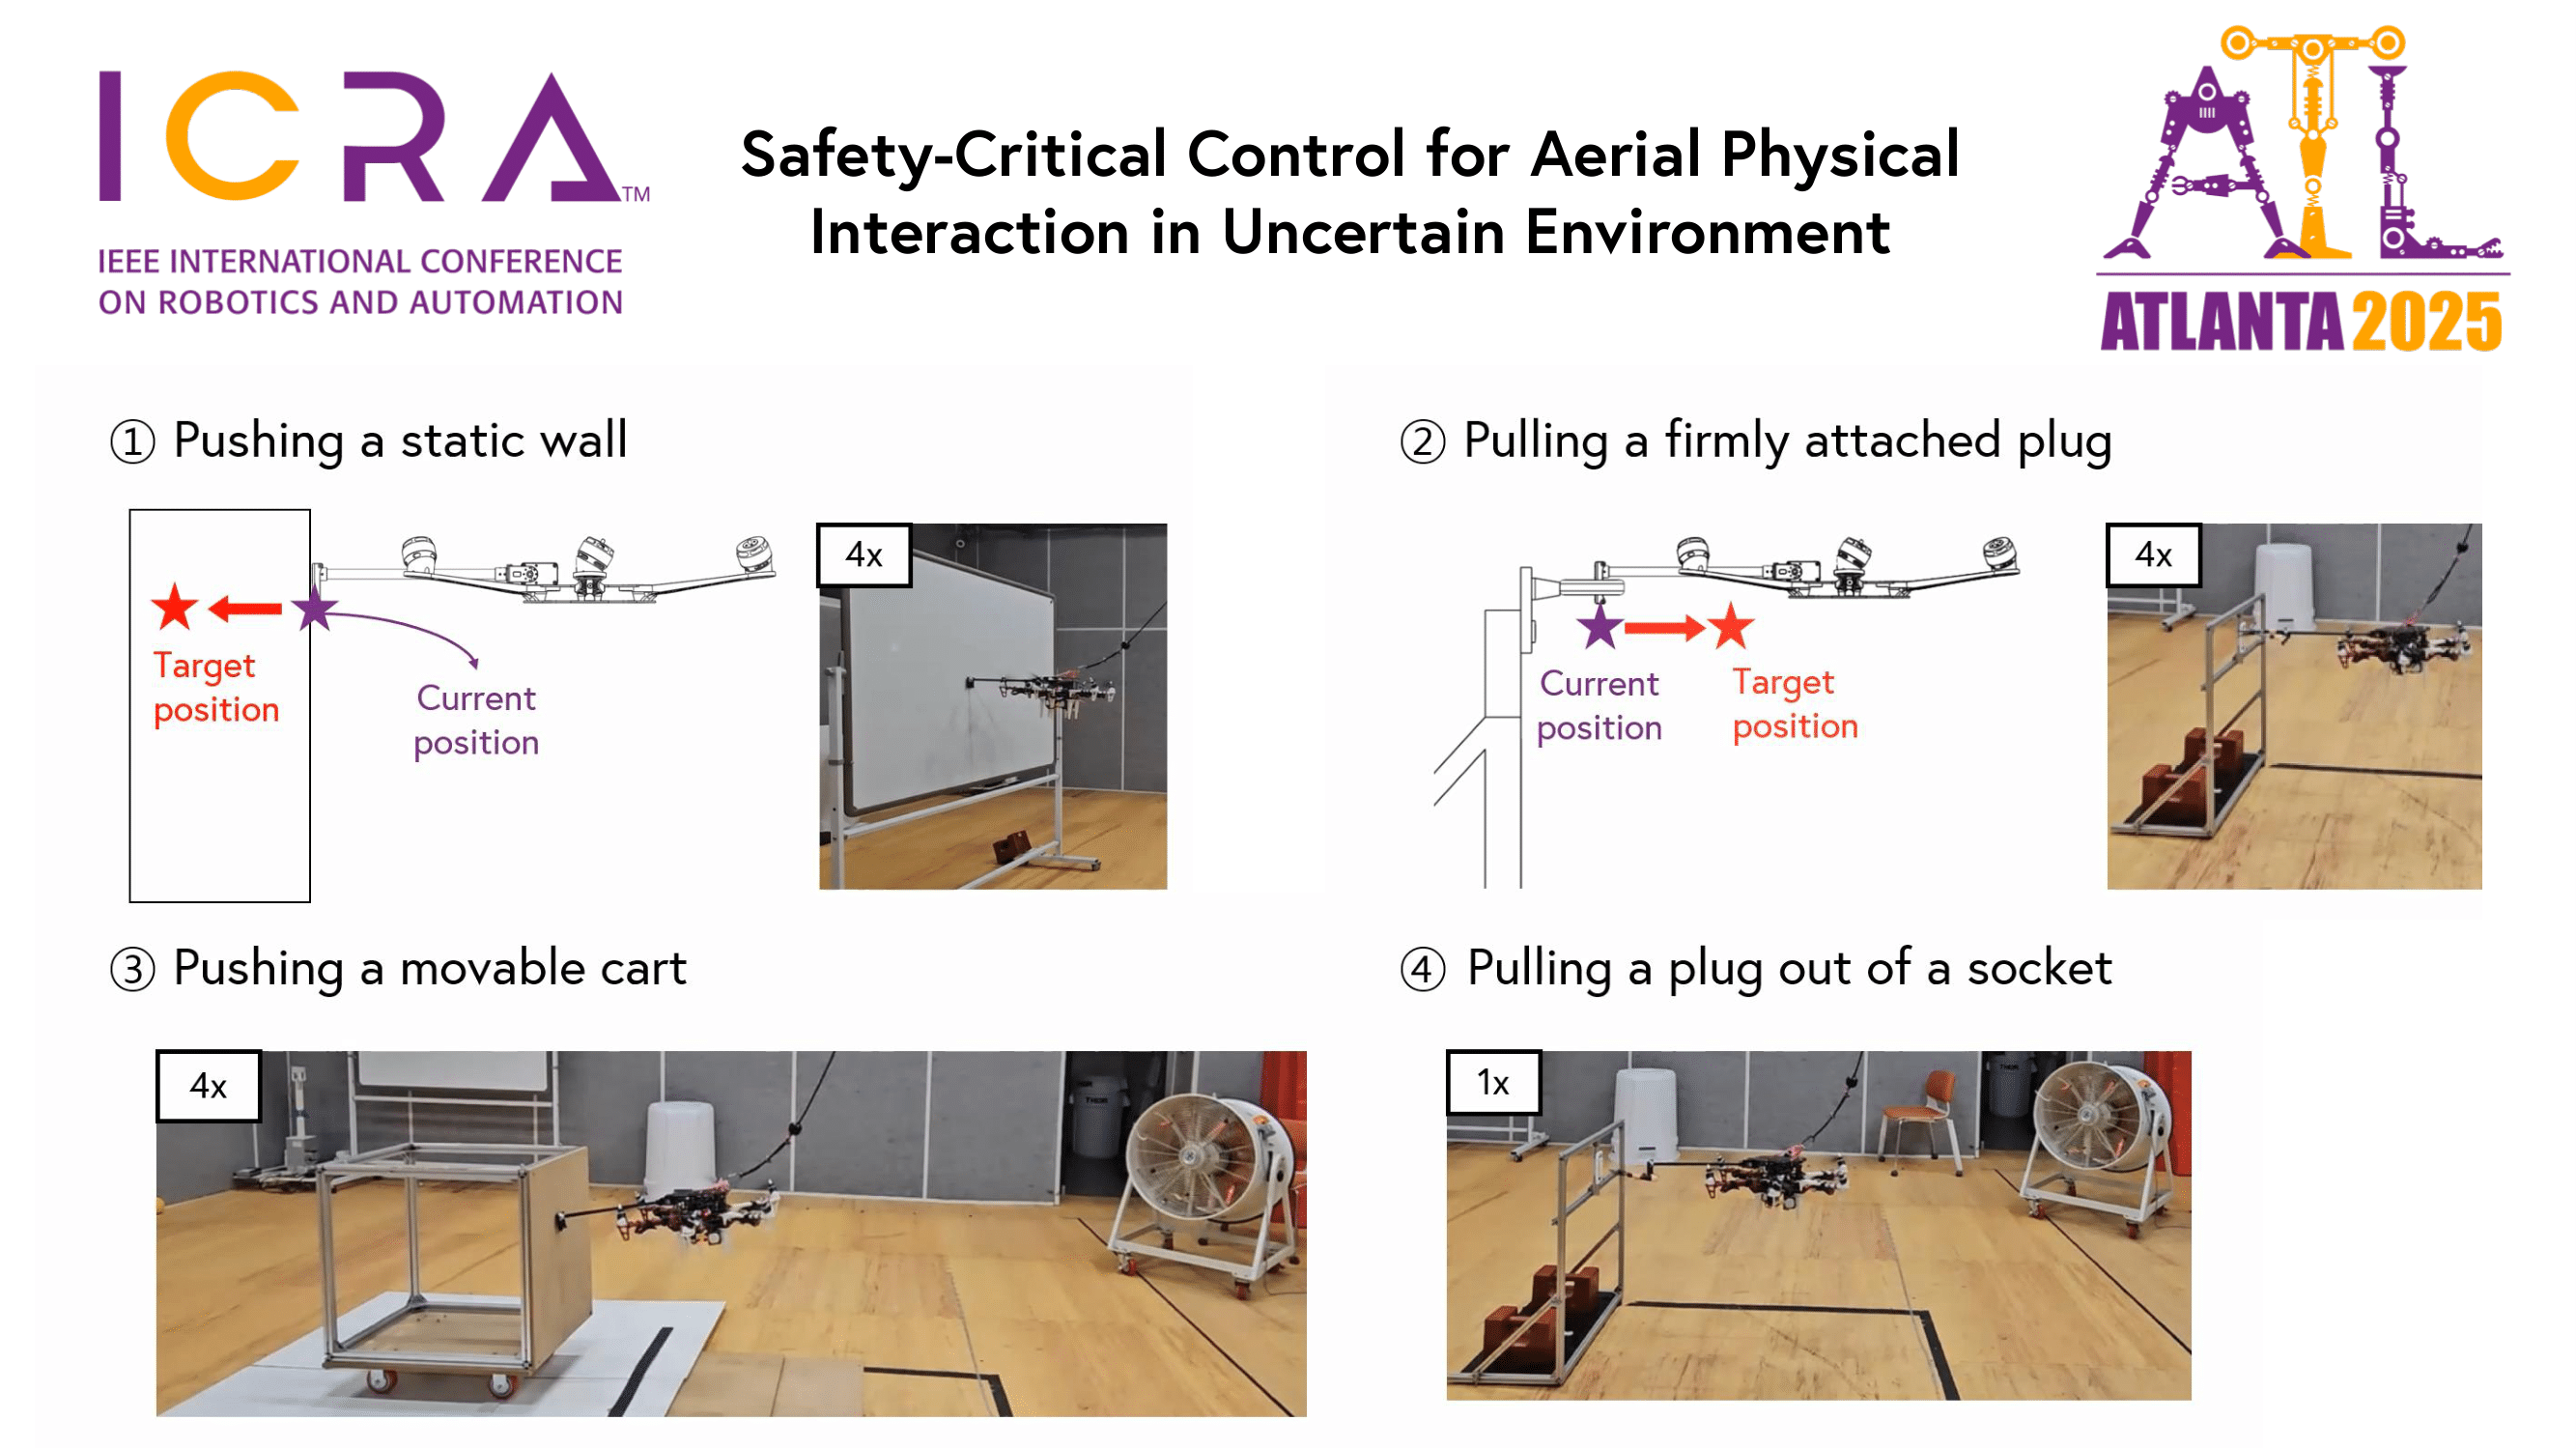
    Safety-critical control for aerial physical interaction in uncertain environment

    Haptic-based bilateral teleoperation of aerial manipulator for extracting wedged object with compensation of human reaction time

    Jeonghyun Byun, Dohyun Eom, and H. Jin Kim

    International Conference on Unmanned Aircraft Systems · 2024
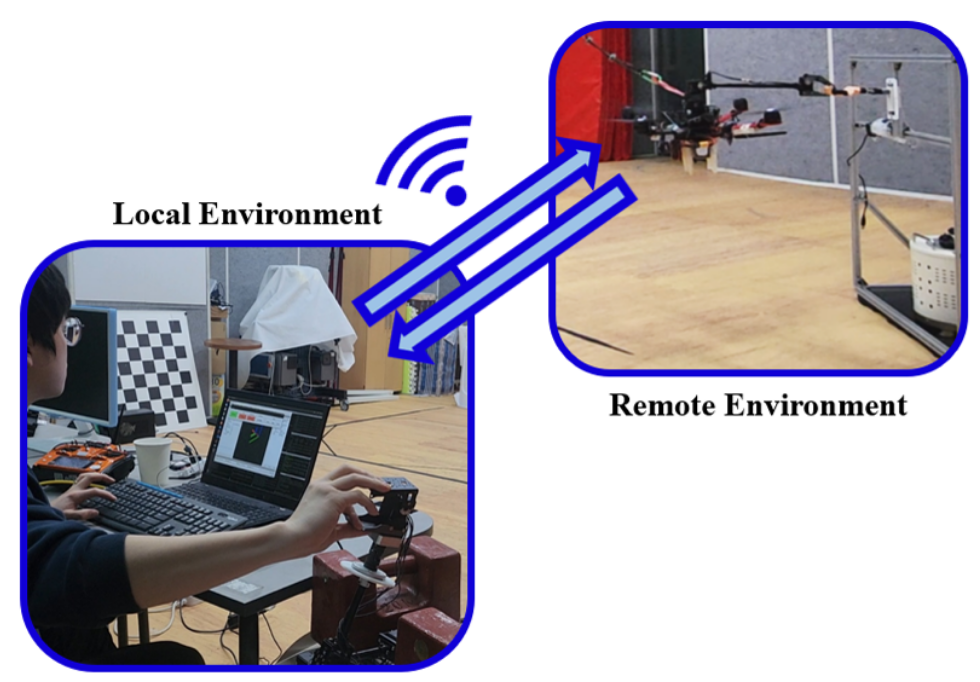
    Haptic-based bilateral teleoperation of aerial manipulator for extracting wedged object with compensation of human reaction time

    Image-based time-varying contact force control of aerial manipulator using robust impedance filter

    Jeonghyun Byun, Junha Kim, Dohyun Eom ,Dongjae Lee, Changhyeon Kim, and H. Jin Kim

    IEEE Robotics and Automation Letters · 2024
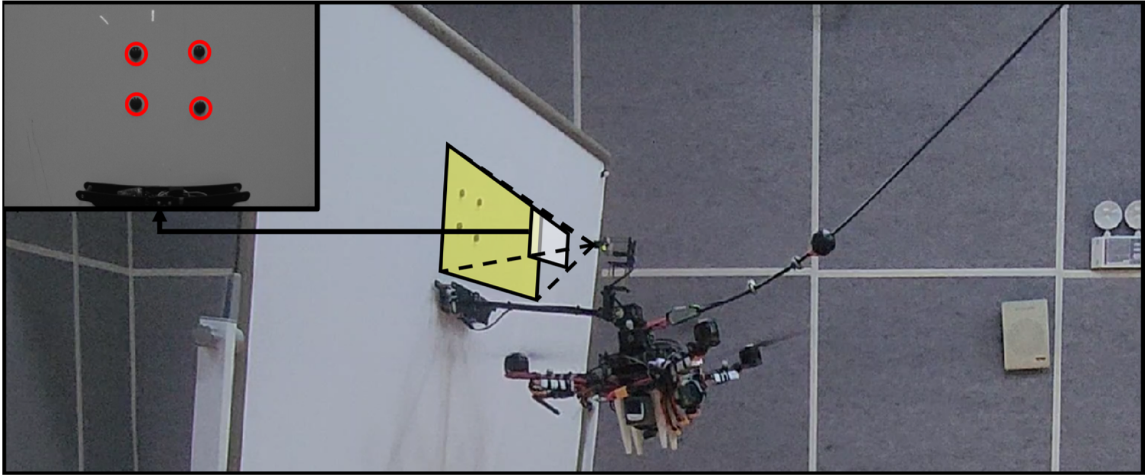
    Image-based time-varying contact force control of aerial manipulator using robust impedance filter

    Autonomous aerial perching and unperching using omnidirectional tiltrotor and switching controller

    Dongjae Lee, Sunwoo Hwang, Jeonghyun Byun, Seung Jae Lee and H. Jin Kim

    IEEE International Conference on Robotics and Automation · 2024
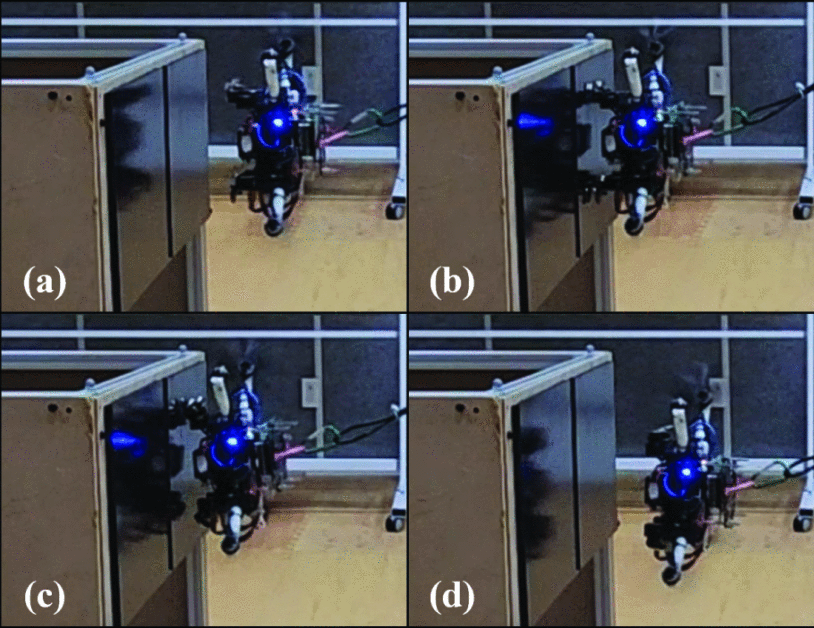
    Autonomous aerial perching and unperching using omnidirectional tiltrotor and switching controller

    Safe receding horizon motion planning with infinitesimal update interval

    Inkyu Jang, Sunwoo Hwang, Jeonghyun Byun, and H. Jin Kim

    IEEE International Conference on Robotics and Automation · 2024
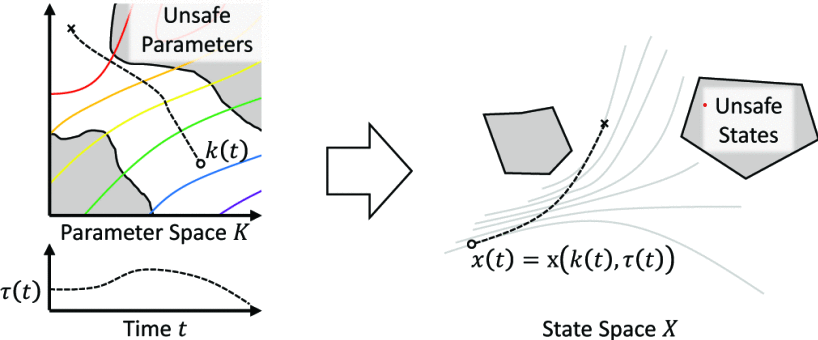
    Safe receding horizon motion planning with infinitesimal update interval

    A hybrid controller enhancing transient performance for an aerial manipulator extracting a wedged object

    Jeonghyun Byun, Inkyu Jang, Dongjae Lee, and H. Jin Kim

    IEEE Transactions on Automation Science and Engineering · 2023
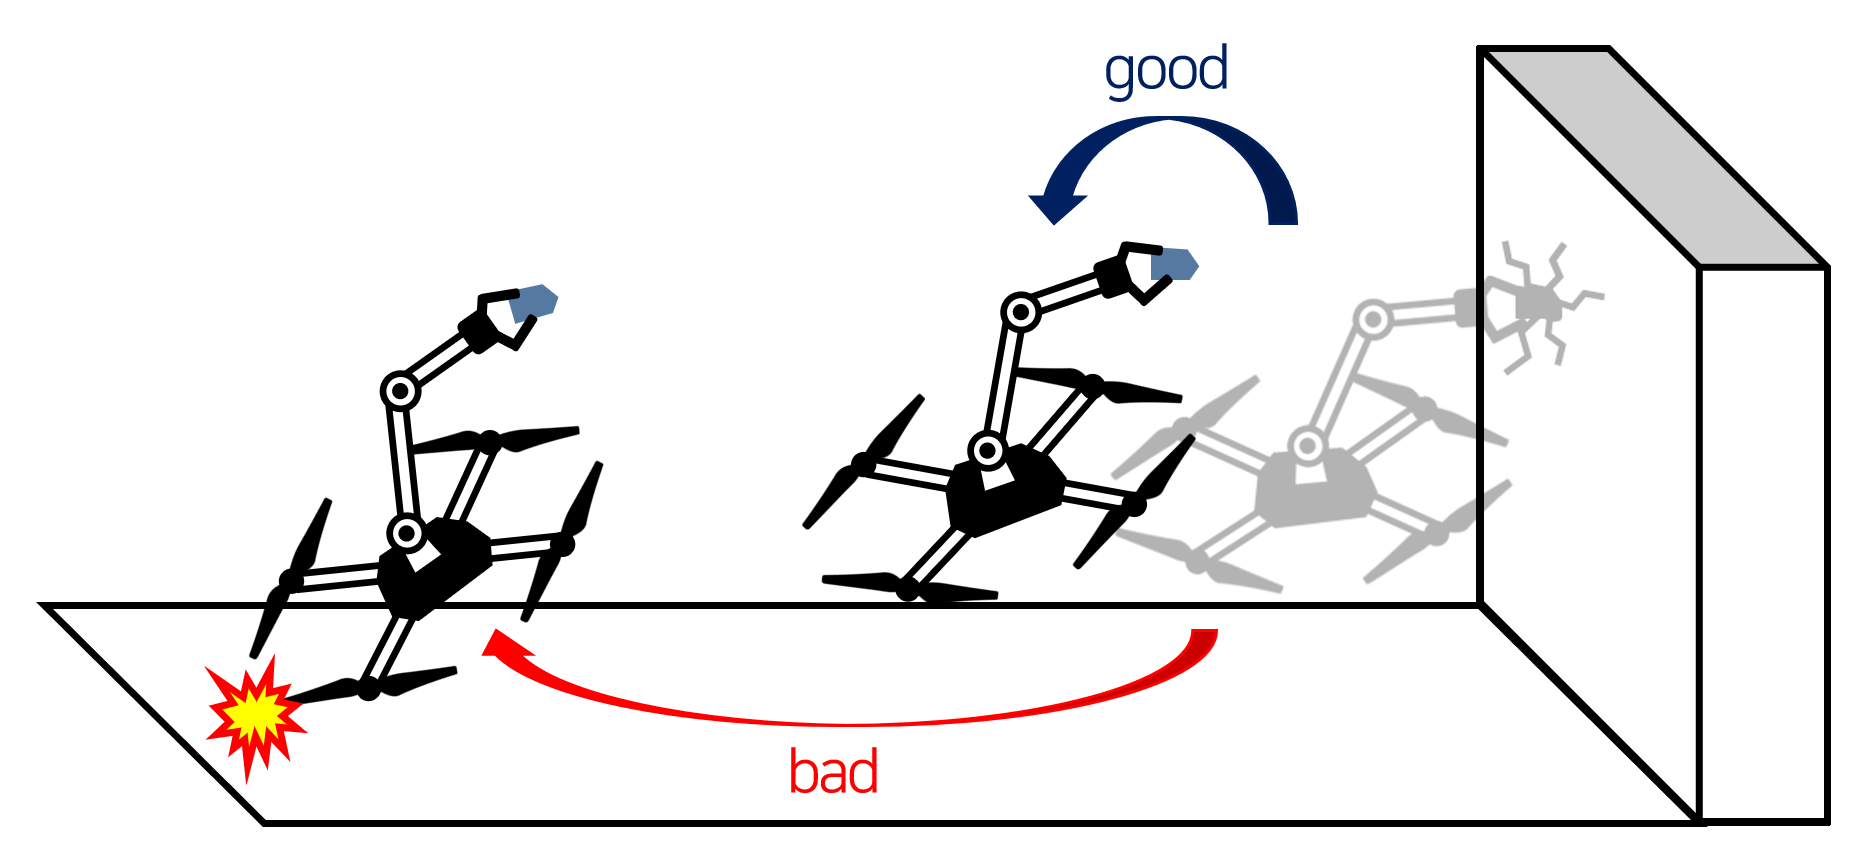
    A hybrid controller enhancing transient performance for an aerial manipulator extracting a wedged object

    Globally defined dynamic modelling and geometric tracking controller design for aerial manipulator

    Byeongjun Kim, Dongjae Lee, Jeonghyun Byun, and H. Jin Kim

    IEEE International Conference on Robotics and Automation · 2023
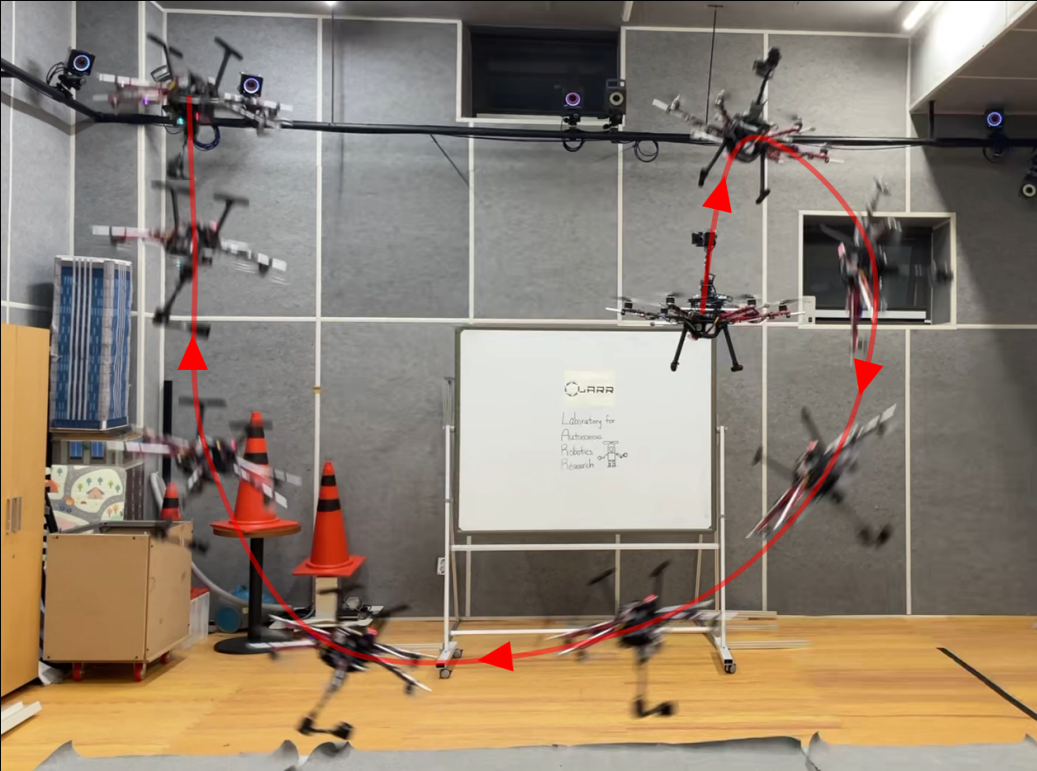
    Globally defined dynamic modelling and geometric tracking controller design for aerial manipulator

    Stable contact guaranteeing motion/force control for an aerial manipulator on an arbitrarily tilted surface

    Jeonghyun Byun, Byeongjun Kim, Changhyeon Kim, Donggeon David Oh, and H. Jin Kim

    IEEE International Conference on Robotics and Automation · 2023
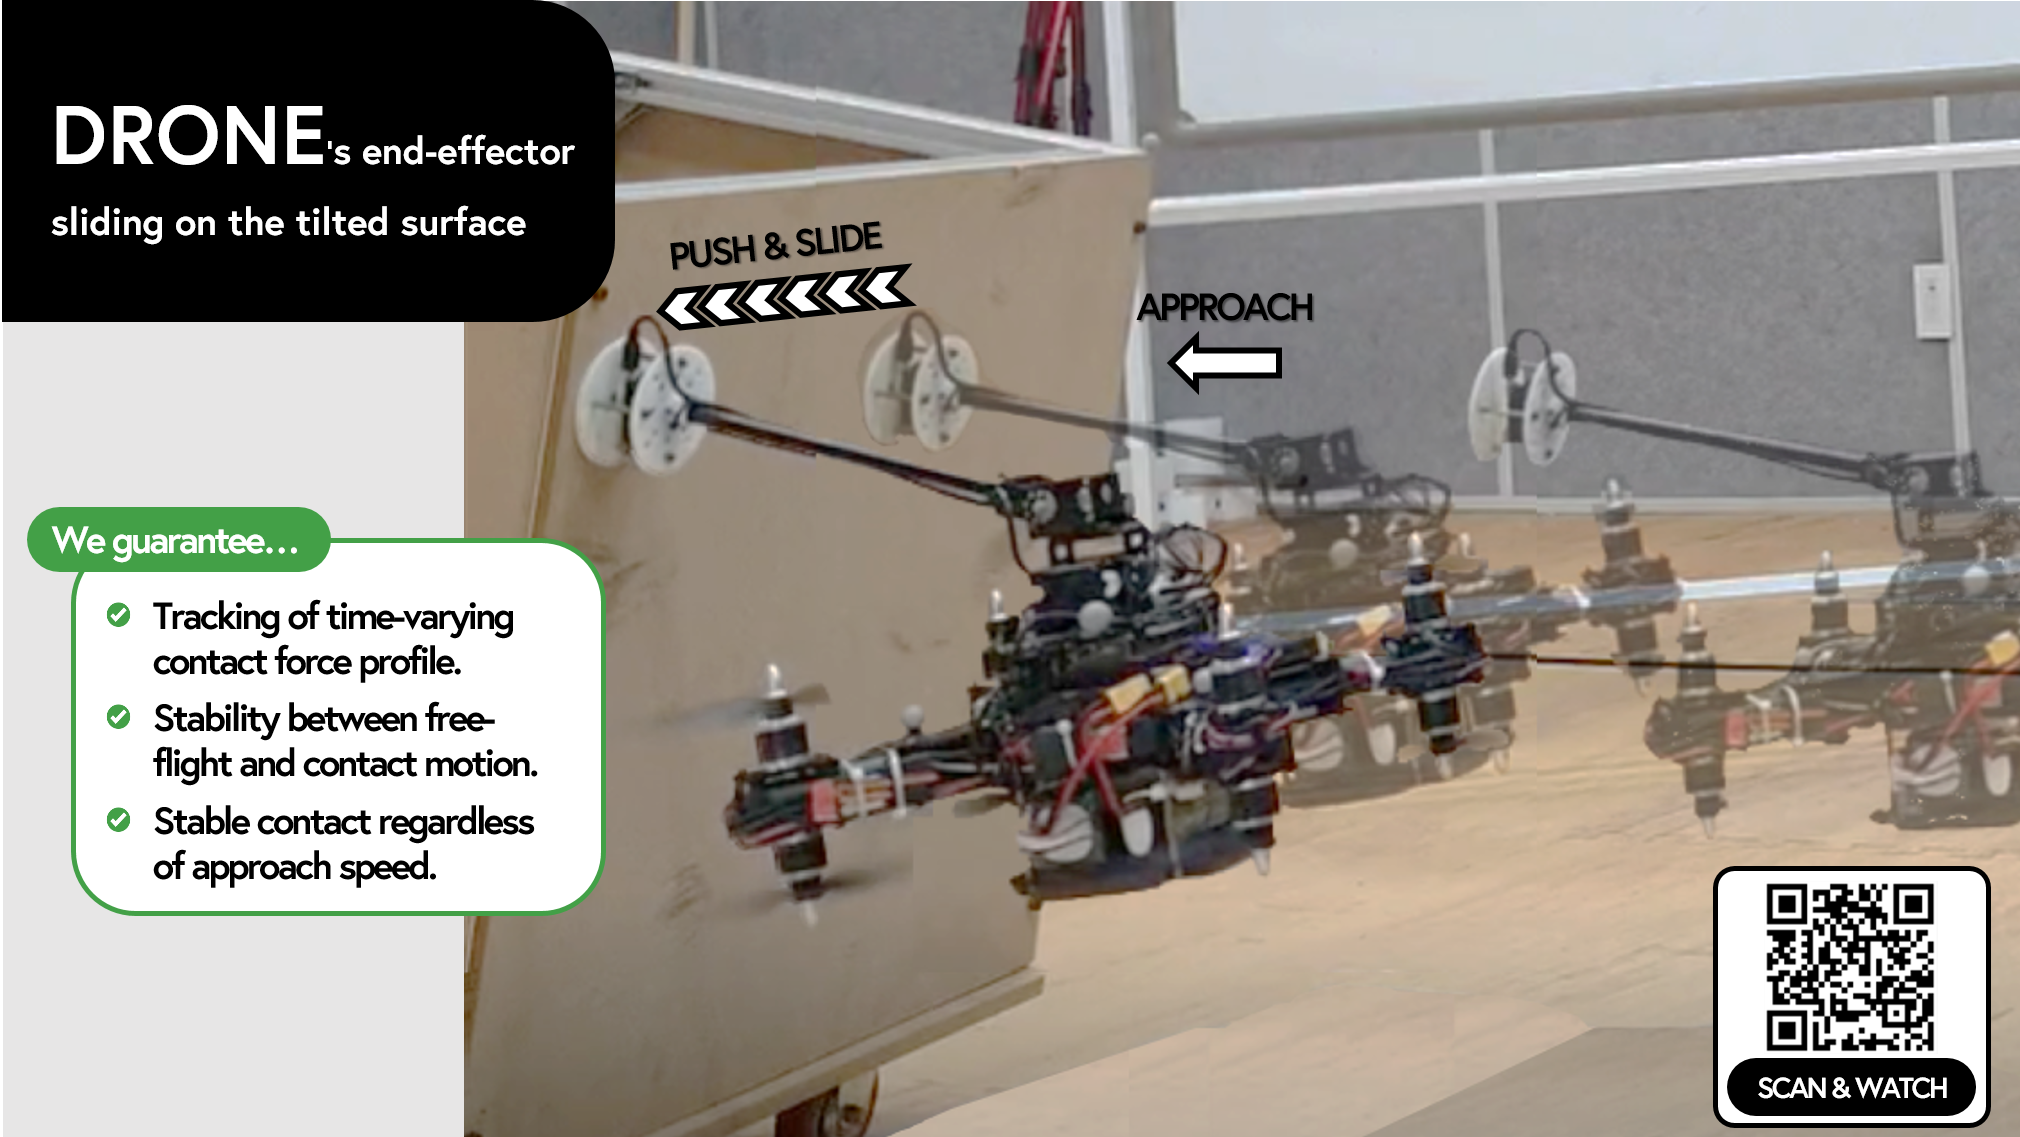
    Stable contact guaranteeing motion/force control for an aerial manipulator on an arbitrarily tilted surface

    Real-time motion planning of a hydraulic excavator using trajectory optimization and model predictive control

    Dongjae Lee, Inkyu Jang, Jeonghyun Byun, Hoseong Seo, and H. Jin Kim

    IEEE/RSJ International Conference on Intelligent Robots and Systems · 2021
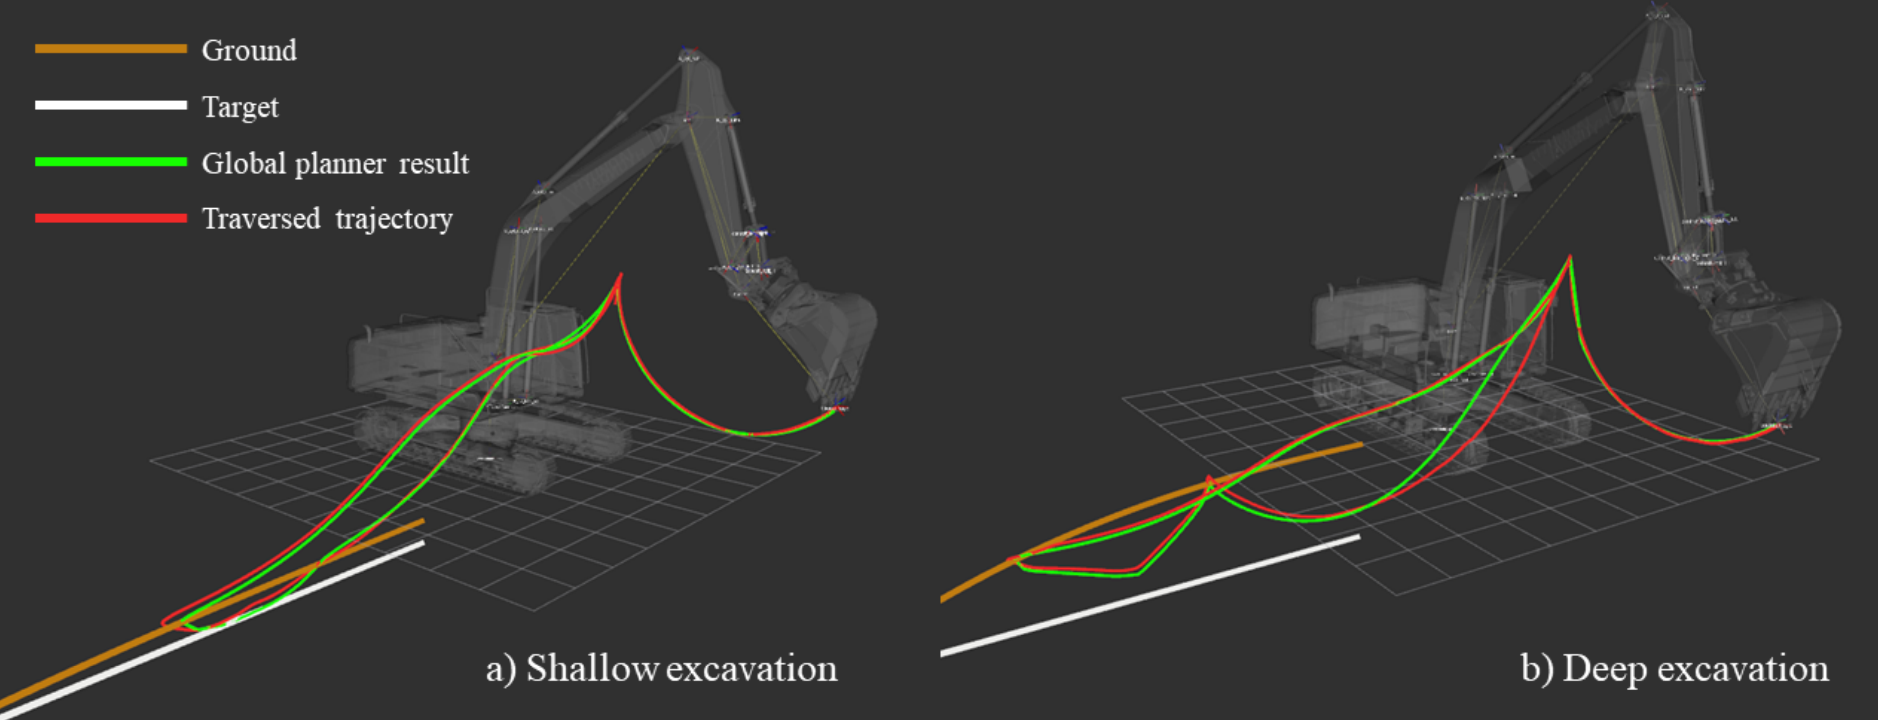
    Real-time motion planning of a hydraulic excavator using trajectory optimization and model predictive control

    Stability and robustness analysis of plug-pulling using an aerial manipulator

    Jeonghyun Byun, Dongjae Lee, Hoseong Seo, Inkyu Jang, Jeongjun Choi, and H. Jin Kim

    IEEE/RSJ International Conference on Intelligent Robots and Systems · 2021
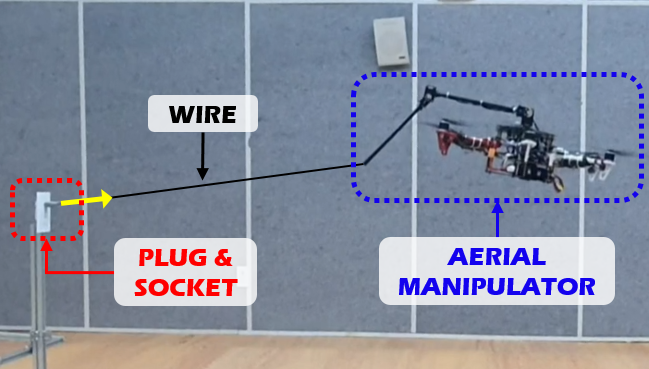
    Stability and robustness analysis of plug-pulling using an aerial manipulator
    • Follow:
    • GitHub
    • Feed
    © 2026 Jeonghyun Byun. Powered by Jekyll & Minimal Mistakes.