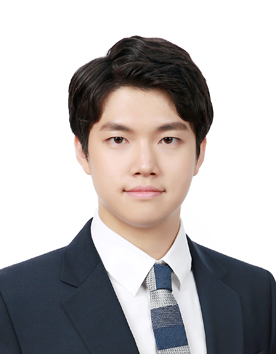
Profile
I develop aerial robots that interact safely and precisely with the physical world, through teleoperation, control, and analysis of omnidirectional aerial manipulation systems.
I am a Fulbright postdoctoral researcher with the Vijay Kumar Group at GRASP, University of Pennsylvania.
Explore my research in action below, or see my CV and research statement for my background and research vision.
|
Saturation-Aware Aerial Manipulation Control |
Image-Based Aerial Force-Tracking Control |
|
Teleoperation of Omnidirectional Tiltrotor |
Plug-pulling with Aerial Manipulator |
Always Open to Work!
If you are interested in fully autonomous aerial manipulation, you can look around our publications and open projects to find an inspiration. Also, you can also contact me using various ways, such as e-mail and linkedin, to discuss the relevant topics.
Purpose of Posting
As a postdoctoral researcher, I am going to share our publications on PUBLICATIONS tab whenever our team publish a paper to conferences or journals and our team’s open projects on STUDY tab. Not only that, my daily life will be posted on BLOG tab. I also want you to enjoy the photos which are uploaded on the PHOTOGRAPHY tab. Please feel free to visit my website!